Missouri S&T Multirotor Design Team
Welcome to the Multirotor Design Team's documentation website! Here, you will find documentation and tutorials relating to the team, including software, firmware, and hardware.
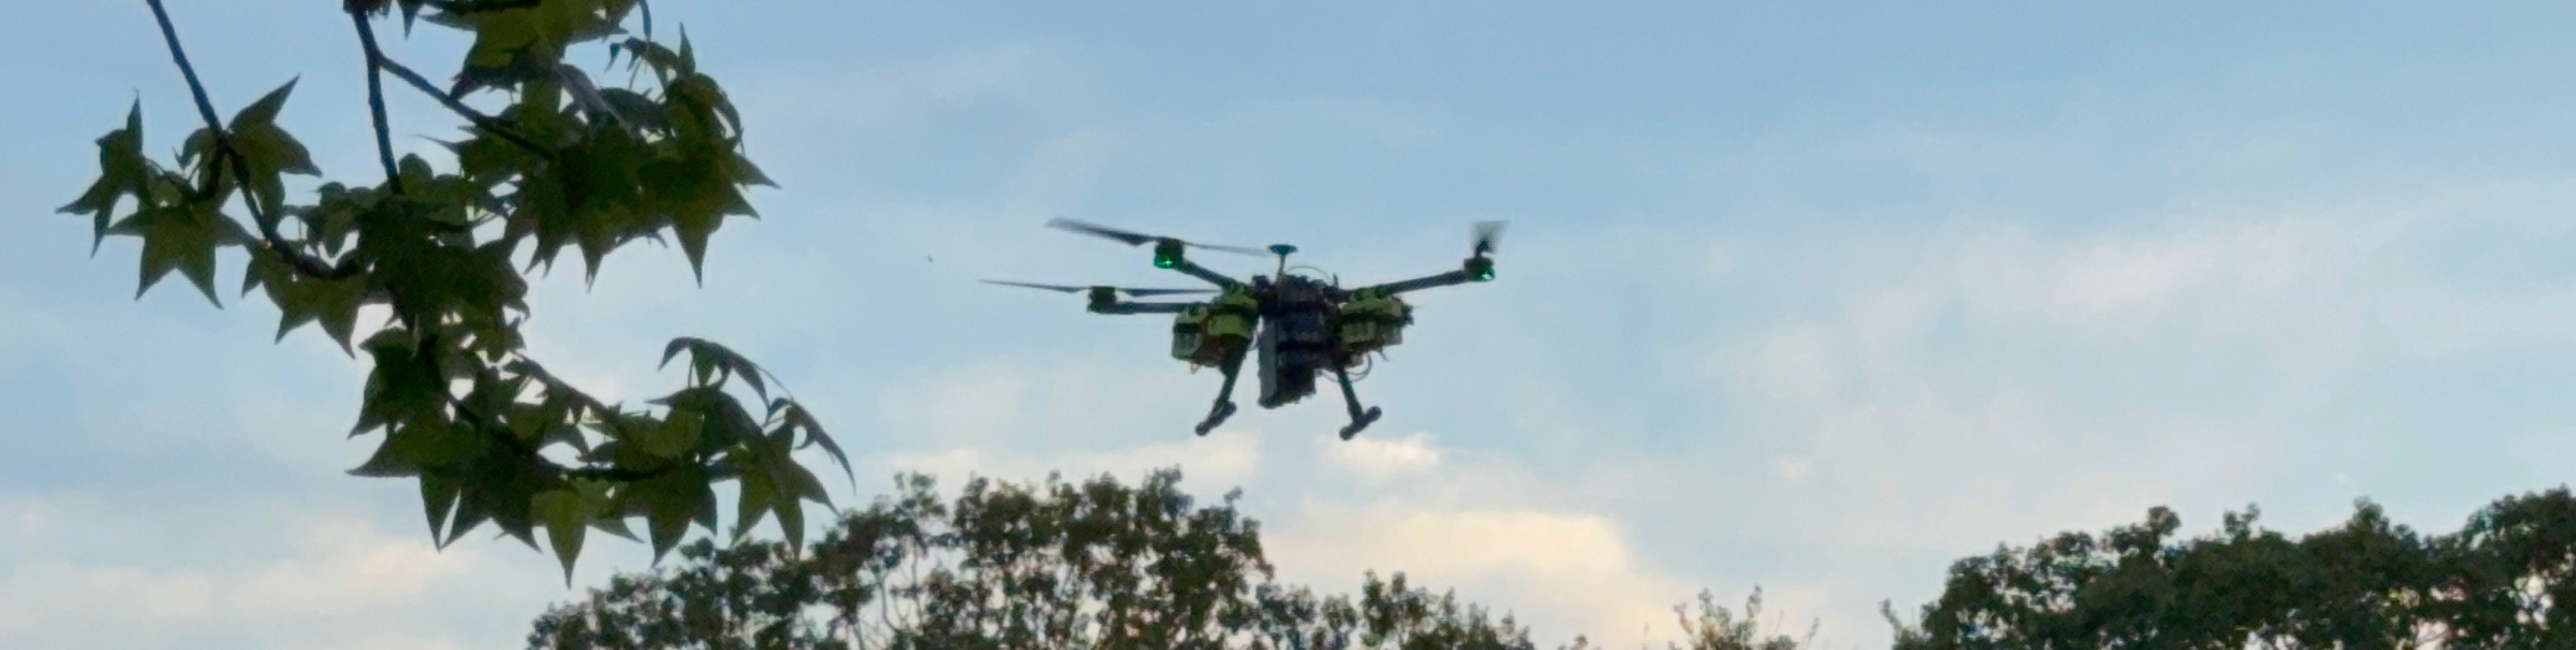
Subteams
Our team has multiple different subteams that focus on different parts of the software and hardware that go into creating a complete autonomous drone.
Software
- Flight - Physical movement of the drone and control of sensors that allow for complex and consistent mission flights
- Vision - Creating vision models that allow for autonomous detection and localization of objects in various environments
- Simulation - Producing simulated environments that match identically to our true competition environments
- Interdrone - Allowing for communication and coordination between multiple drones
Hardware - Design and construction of all of our competition drones, including both mechanical and electrical scopes
Firmware - Configuration of the flight firmware (ArduPilot) that runs on the flight controllers we use
Tools and Technologies
Competition Codebases
- IARC-10 (2026-27)
- SUAS-2026
- SUAS-2025
- SUAS-2023 (2023-24)
- SUAS-2022
- IARC-2020
- IARC-2019
- IARC-2018
- DroneKit (2016-17)
- Panic (2016)
Editing this Documentation
This website was built using Zensical, and the source code is hosted on the team's GitHub repository. Want to modify existing pages or add new pages? See the Zensical section.